Justin Chae
Mechanical & product design engineer. Robots, actuators, and small hardware, end to end.
Open to full-time roles
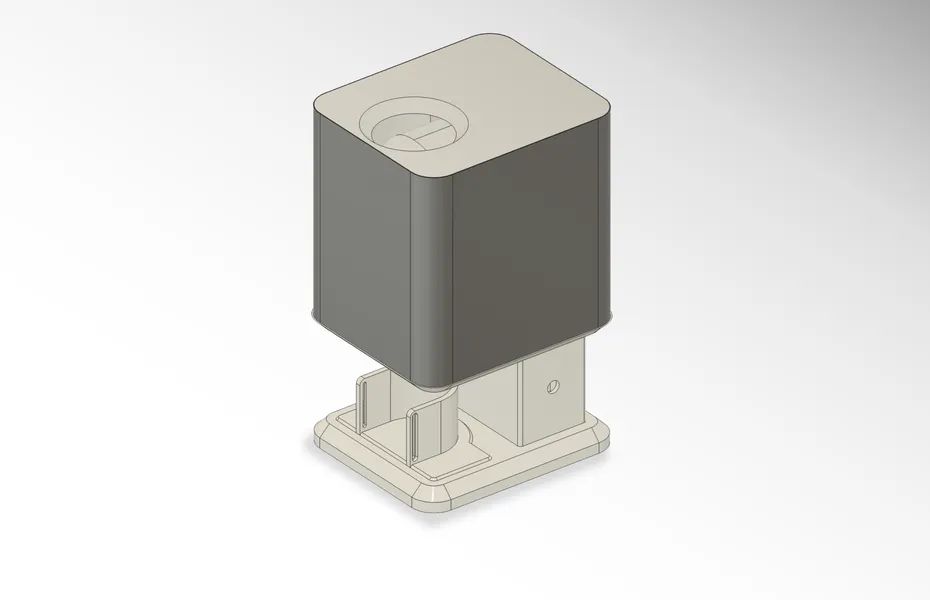
Motorized Coffee Bean Grinder Conversion
Motorizing a Kingrinder K6 hand grinder: from hand-crank torque testing and motor sizing to a belt-driven build with a formed aluminum shroud.
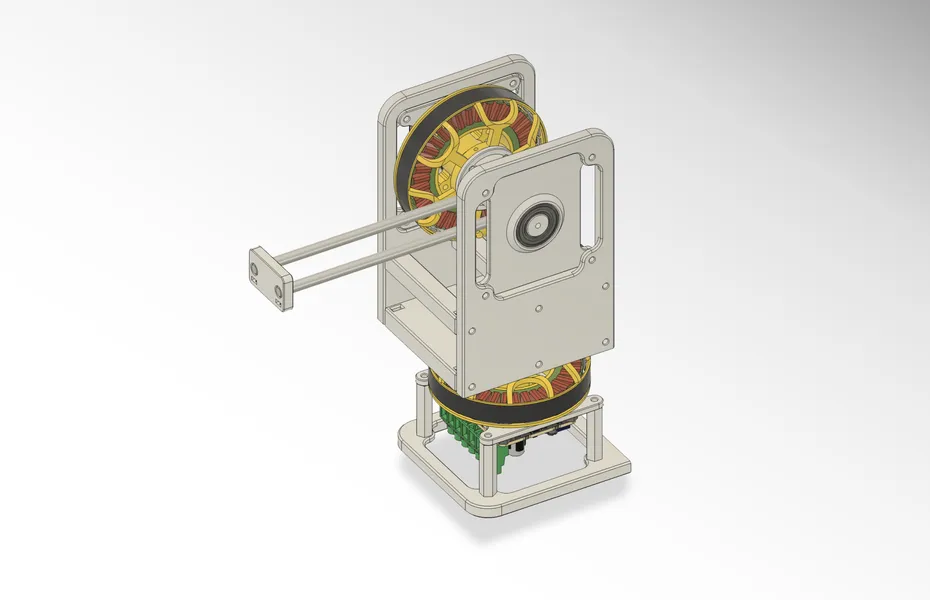
Cup Pong Robot
A robot built to beat anyone at cup pong: a direct-drive BLDC catapult on a camera-guided pan axis, calibrated from slow-motion video and run from a Raspberry Pi web app.
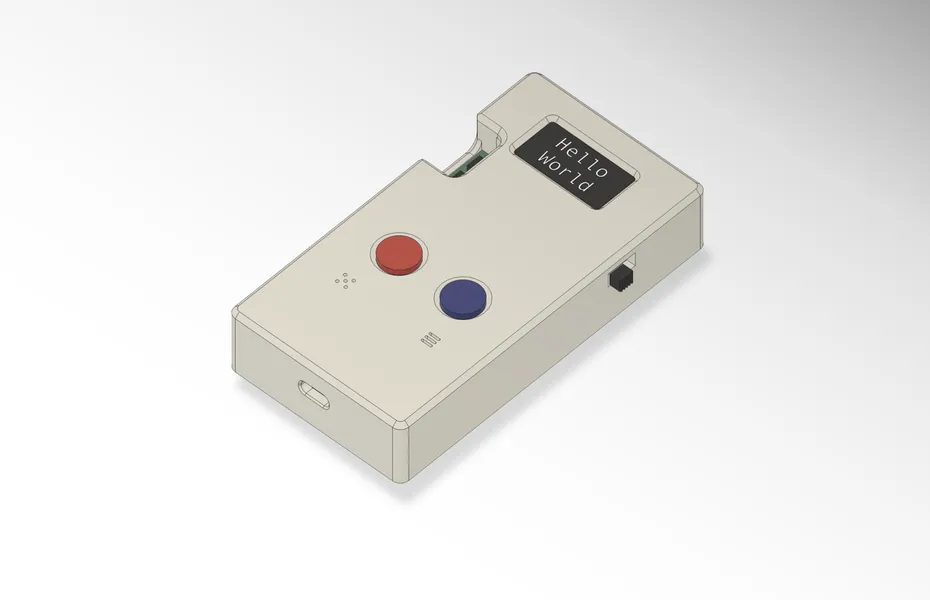
Pokodoro
A portable, haptic-feedback Pomodoro timer with a custom PCB, ESP32, and OLED display — because a vibration is a less intrusive way to know your session's up than a beep.
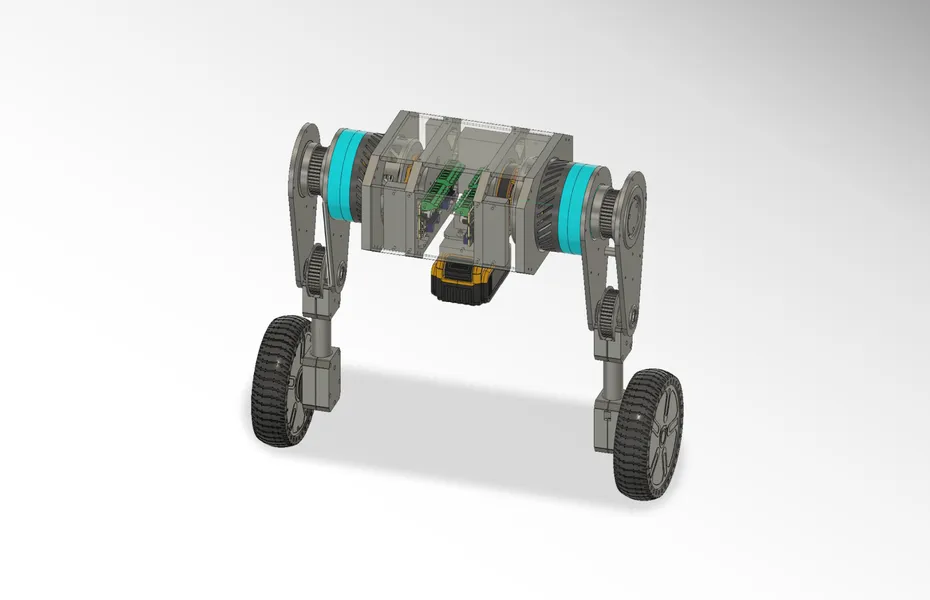
Wheeled Bipedal Robot
A low-cost, DIY-buildable wheeled bipedal robot with 6 actuated joints, designed, built, and coded solo in 8 months for under $1,750.
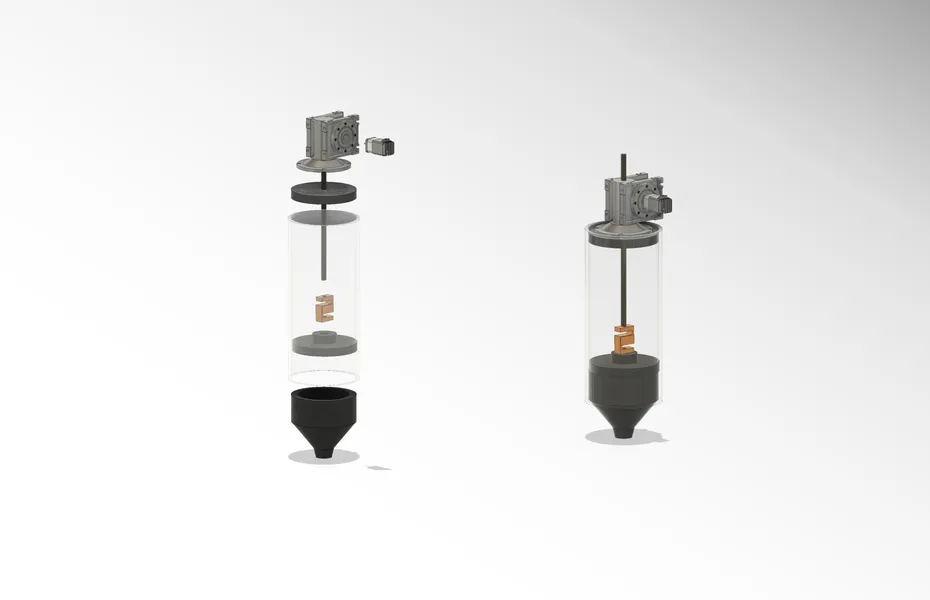
Load Cell Extrusion Control
A closed-loop feedback system to catch under- and over-extrusion in a 3D ceramic printer, using real-time pressure data from a load cell.
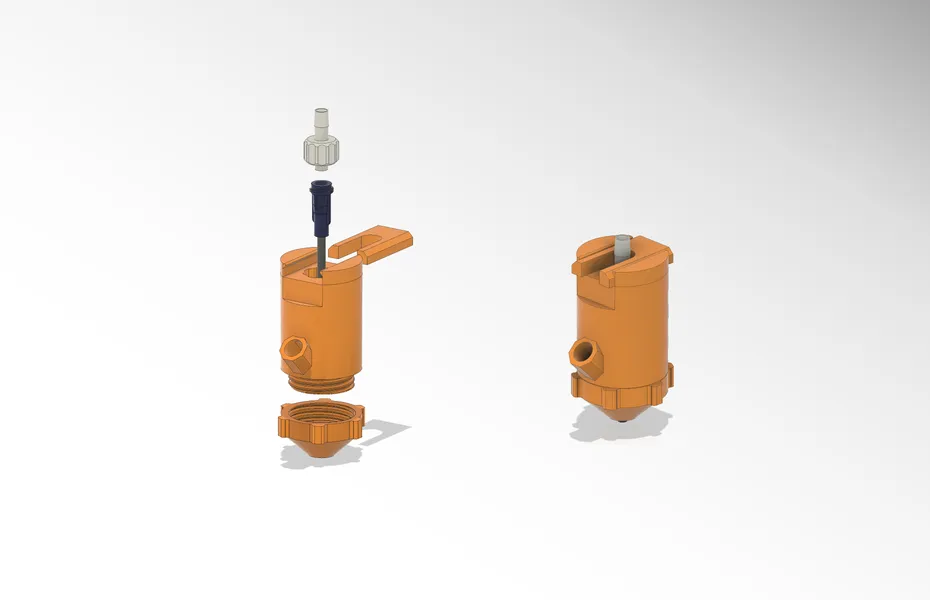
Coaxial Nozzle Design
A dual-material 3D-printable nozzle for coaxial extrusion, developed in Princeton's Architected Materials and Additive Manufacturing Lab.
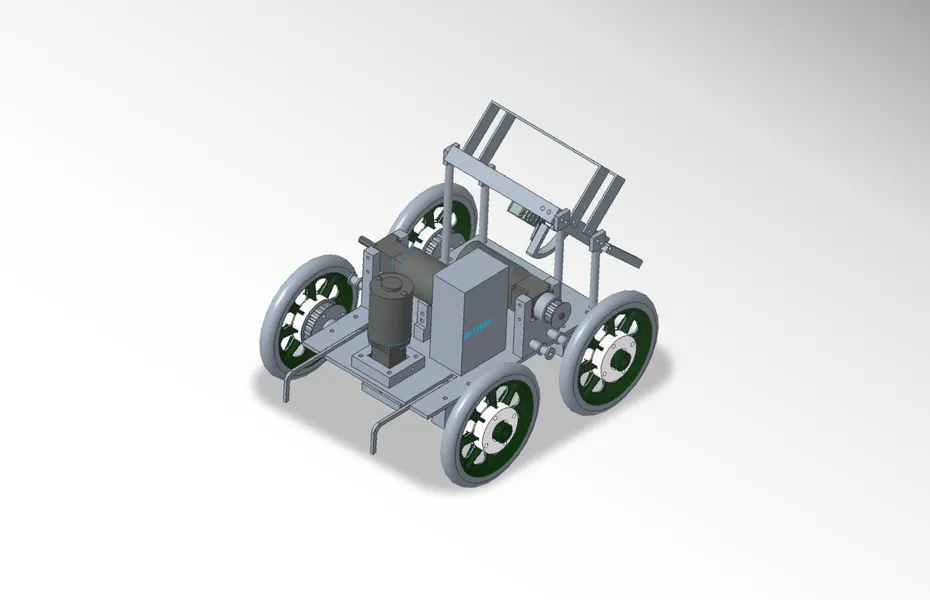
Search and Rescue Robot
A search-and-rescue robot that navigated an obstacle course, breached a wall, and autonomously delivered a medical kit — built by a 6-person team I led.